Haptics
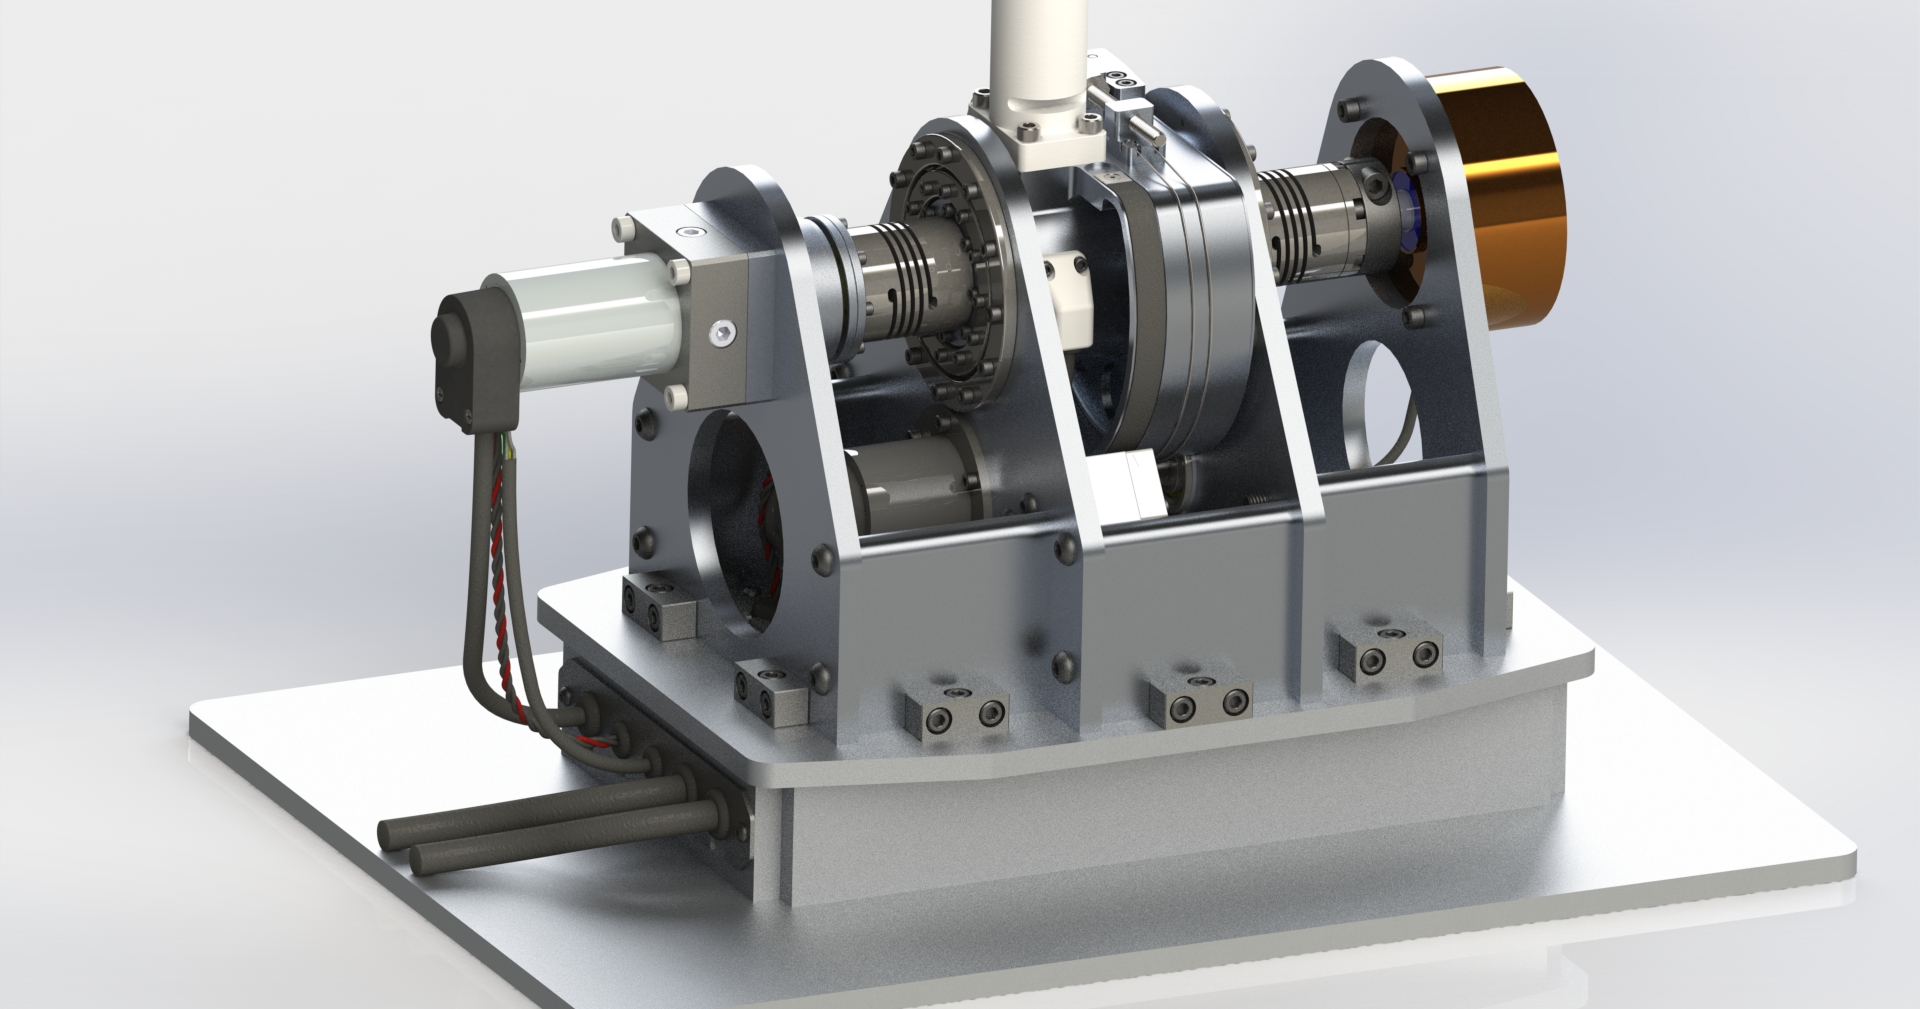
The REACH lab has been at the forefront of kinesthetic haptic interface research. We have addressed challenges in merging the competing characteristics required for effective performance including high force and high dynamic range with those required for inherent safety and dexterity, including low output impedance, transparency, and wide–band frequency force/torque content. In seeking solutions, we have investigated novel actuation and control topologies including parallel macro–mini approaches and hybrid active–passive actuation approaches and have explored various control methods that extend impedance and admittance–based formulations. The research has resulted in novel actuation approaches that have extended the capabilities of kinesthetic haptic interfaces, allowing for force, power, transparency and rendering ranges that significantly exceed those of state–of–the–art interfaces. The research results have applications in physically–assistive systems, rehabilitation devices, medical robotics, automation, and manufacturing, to name a few.
Collaborators
- Michael Zinn – Department of Mechanical Engineering, University of Wisconsin–Madison
- Nicholas Colonnese – Facebook Reality Lab, Inc.
- Peter Adamczyk – Department of Mechanical Engineering, University of Wisconsin – Madison
Students
- Patrick Dills
- Bolun Zhang
- Megh Doshi
- It Fufuengsin
- Chembian Parthiban
Funding
- National Science Foundation (NSF) – NRI
- Facebook Reality Labs, Inc.
Hybrid Handheld Haptics
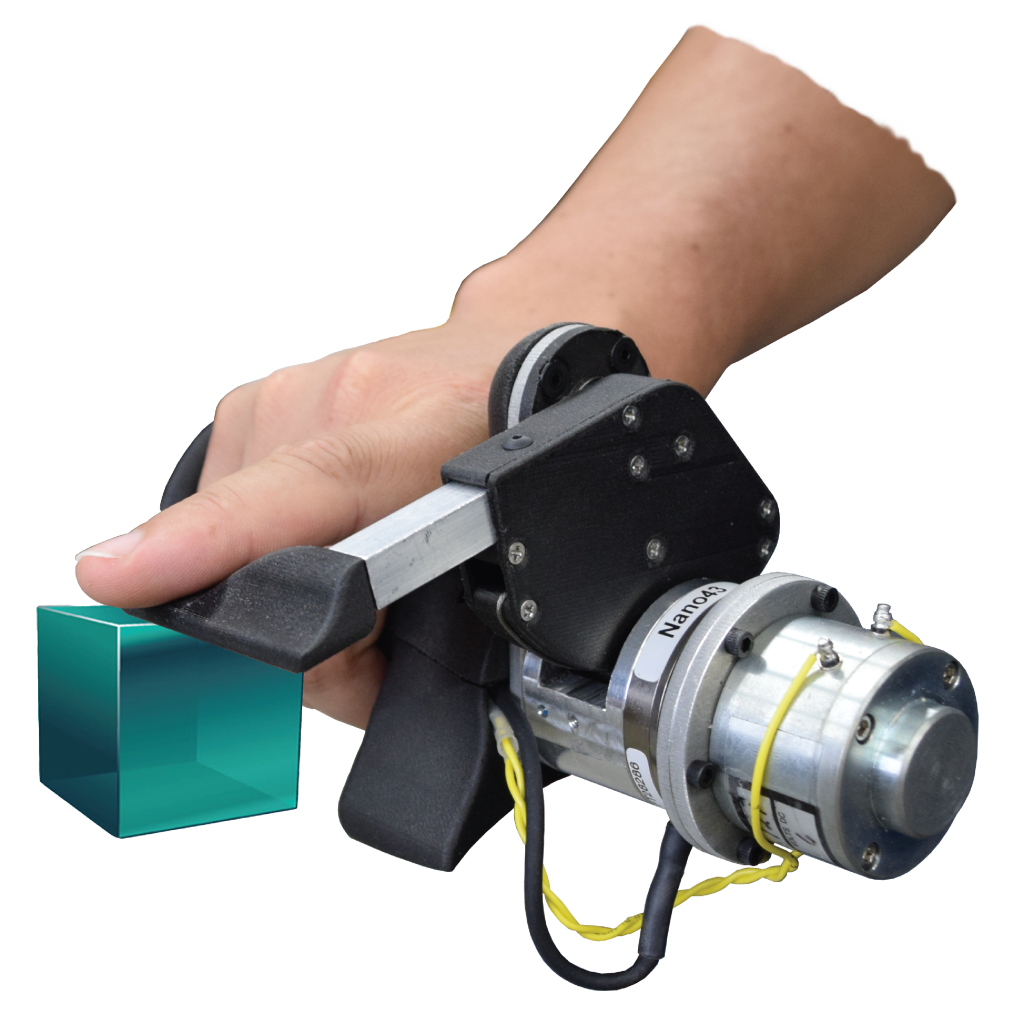
Handheld haptic devices are often limited in rendering capability. We design high-performance mobile devices with hybrid actuation
Hybrid 2-DOF Robot
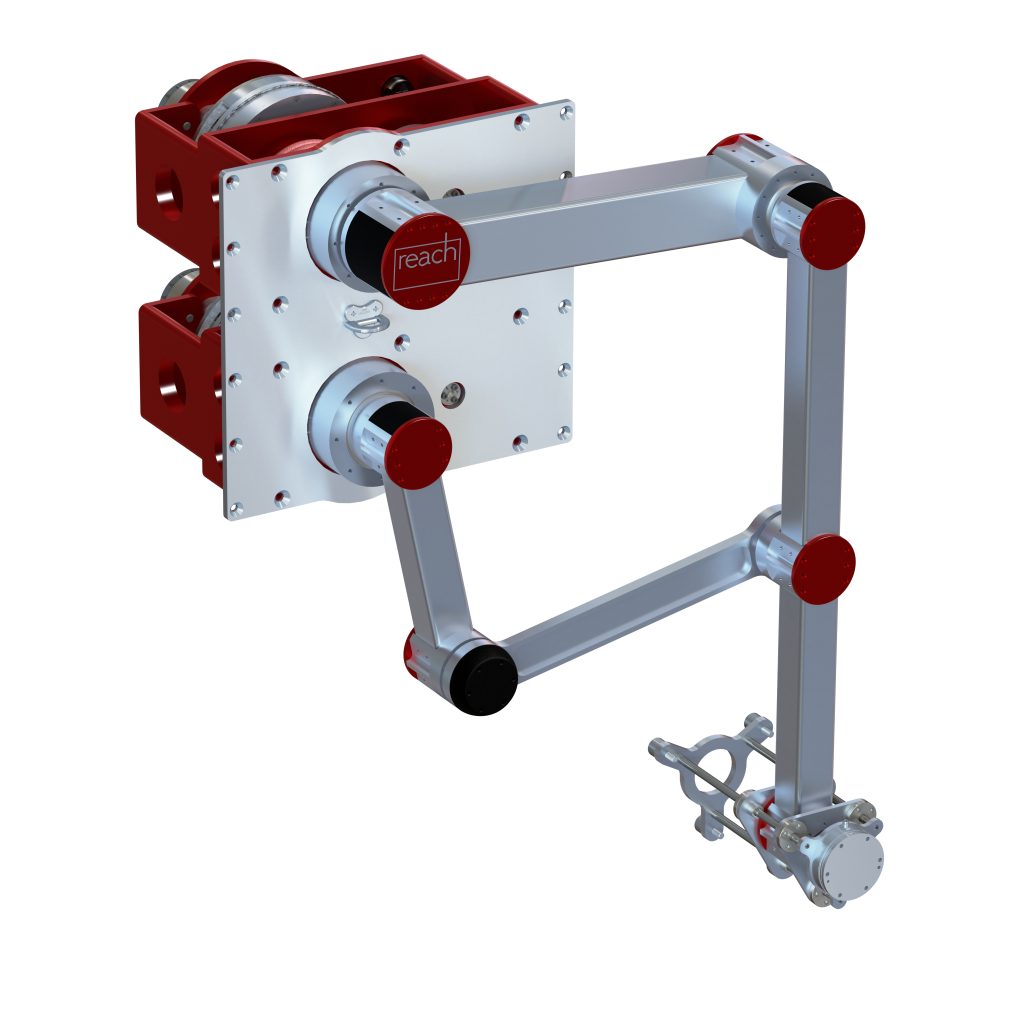
We are developing a two degree-of-freedom hybrid actuator to be used for lower-limb rehabilitation applications
Haptic Perception
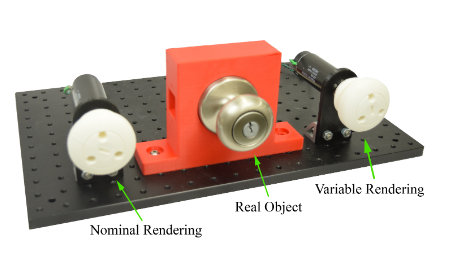
We assess the effect of haptic parameter variations on perceived realism.
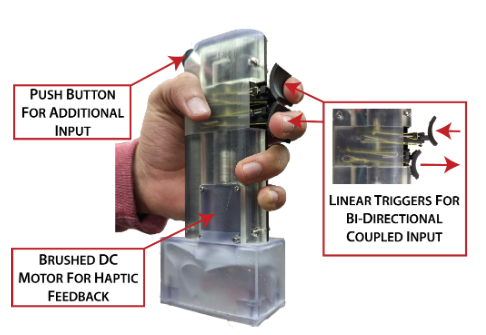
Bidirectional Input
We are developing a custom haptic input for differential input using finger flexion.
- Zhang, B., M. Gleicher, M. Hagenow, B. Mutlu, and M. Zinn. Assessing the Perceived Realism of Kinesthetic Haptic Renderings Under Parameter Variations. IEEE Haptics Symposium (HAPTICS), 2022. YouTube.
- Dills, P., K. Gabardi, and M. Zinn. “Stability and Rendering Limitations of High-Performance Admittance Based Haptic Interfaces”. IEEE Haptics Symposium (HAPTICS), 2022, p. 8. Supplementary material. YouTube.
- Dills, P., A. Dawson-Elli, K. Gruben, P. Adamczyk, and M. Zinn. “Stability and Rendering Limitations of a Parallel Hybrid Active-Passive Haptic Interface”. IEEE Haptics Symposium (HAPTICS), 2022, p. 8. YouTube.
- Gabardi, K., P. Dills, B. Zhang, and M. Zinn. “Factors Affecting the Stable Range of Damping and Mass in Admittance Type Haptic Devices”. IEEE World Haptics Conference (WHC), 2021, p. 1.
- Dills, P., N. Colonnese, P. Agarwal, and M. Zinn. “A Hybrid Active-Passive Actuation and Control Approach for Kinesthetic Handheld Haptics”. IEEE Haptics Symposium (HAPTICS), 2020, p. 8. YouTube.
- Parthiban, C., P. Dills, I. Fufuengsin, N. Colonnese, P. Agarwal, and M. Zinn. “A Balanced Hybrid Active-Passive Actuation Approach for High-Performance Haptics”. IEEE World Haptics Conference (WHC), 2019, p. 6. YouTube.
- Dills, P., C. Parthiban, I. Fufuengsin, N. Colonnese, P. Agarwal, and M. Zinn. “Design and Analysis of a High Performance Impedance Based Hybrid Haptic Interface”. IEEE Haptics Symposium (HAPTICS), 2018, p. 3.
- Zhang, B., M. Gleicher, M. Hagenow, B. Mutlu, and M. Zinn. Characterizing the Effects of Haptic Rendering Parameter Variations on Perceived Kinesthetic Rendering accuracy.